Introduction
For highway operators and road weather monitoring projects, fog is not only a weather condition but also a rapidly changing visibility problem. Visibility can drop within minutes on highways, bridges, mountain roads, and tunnel approaches, making periodic manual observation insufficient for continuous monitoring. A fog visibility sensor provides real-time visibility data so operators can identify low-visibility conditions and respond based on measured changes rather than visual judgment alone.
So, how does a fog visibility sensor work? It uses optical technology to detect light scattered by fog droplets and other airborne particles, then processes the optical signal to estimate visibility, commonly expressed as Meteorological Optical Range (MOR). The resulting data can be transmitted to a road fog monitoring system for real-time display, warning, traffic management, and integration with broader road weather monitoring systems.
This article explains the measurement principle behind fog visibility sensors, the factors that affect roadside measurements, and how the sensor is integrated into practical highway safety applications.If you want to understand the basic function and applications of these devices,see [What Is a Visibility Sensor].
How Does a Fog Visibility Sensor Work?
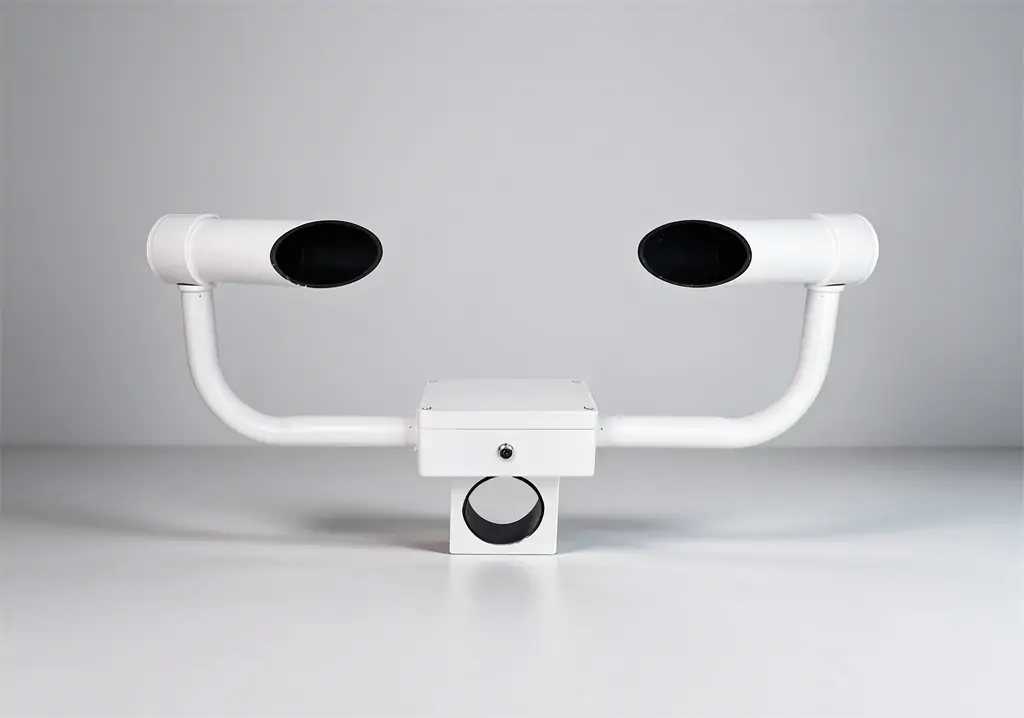
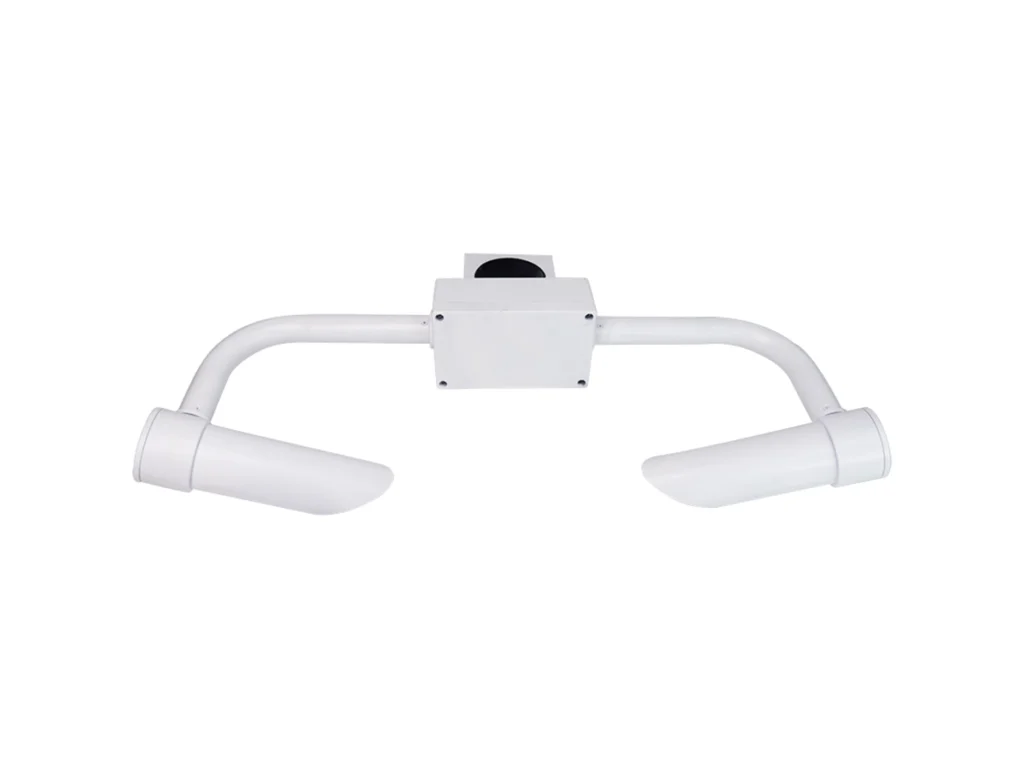
A fog visibility sensor measures the light scattered by suspended fog droplets and other airborne particles within a defined sampling volume. In a typical forward-scatter design, an optical emitter sends a controlled light beam through the sampling volume, while a receiver positioned at a specific angle detects part of the light scattered by particles in the air. The measured scattered light is converted into an electrical signal that represents the optical condition of the sampled atmosphere.
The sensor does not directly measure how far a person can see. Instead, its processing unit uses the measured optical response to estimate the atmospheric extinction coefficient (σ), which describes how strongly the atmosphere attenuates light. The sensor can then derive Meteorological Optical Range (MOR) from the extinction coefficient based on the relationship commonly associated with Koschmieder’s law:
MOR ≈ 3 / σ
As atmospheric extinction increases, light is attenuated more strongly and the calculated MOR decreases, indicating lower visibility. When extinction decreases, MOR increases, indicating better visibility.
In simplified form, the measurement process can be understood as:
Light emission → Particle scattering → Optical signal → Extinction coefficient → MOR → Visibility data
The key point is that a fog visibility sensor does not directly measure distance. It measures the optical properties of the atmosphere and processes the resulting signal into a standardized visibility parameter. This distinction is important when evaluating how visibility data is generated and how the sensor performs under changing outdoor conditions.For a broader explanation of how visibility is measured, see ourguide to [How Is Visibility Measured].
Why Is Forward Scattering Widely Used for Road Fog Monitoring?
Road fog can vary significantly over short distances, especially around bridges, valleys, mountain roads, and tunnel approaches. For this reason, a road monitoring network often needs multiple measurement points rather than a single visibility instrument covering a long section of roadway. Forward-scatter sensors are well suited to this distributed approach because the optical components can be integrated into a relatively compact instrument and measure visibility within a local sampling volume.To learn more about highway visibility monitoring and how visibility sensors are used in road safety applications, see Highway Visibility Sensor: Applications for Road Safety Monitoring.
Forward Scatter vs. Transmissometer
The main difference from a transmissometer is the measurement configuration. A transmissometer uses a separated transmitter and receiver to measure light attenuation across a defined optical path, while a forward-scatter sensor measures scattered light within a localized sampling volume. This makes the two methods suitable for different installation requirements.
| Measurement method | Measurement configuration | Road monitoring characteristic |
| Forward scatter | Measures scattered light within a local sampling volume | Compact and suitable for distributed monitoring points |
| Transmissometer | Measures light attenuation across a defined optical path | Requires separated optical units and a fixed measurement path |
| Backscatter | Measures light scattered back toward the source | Compact, but uses a different optical geometry |
For highway monitoring, the practical value of forward scattering is therefore deployment flexibility rather than simply higher measurement performance. A compact sensor can be installed at selected locations where local fog conditions are known to change quickly, and its visibility data can be transmitted to a road fog monitoring system for continuous observation and further decision-making.
The choice of measurement technology should still depend on the required visibility range, measurement environment, installation conditions, accuracy requirements, and system architecture. Forward scattering is widely used because its compact configuration fits the needs of distributed roadside monitoring, not because it is universally superior to other visibility measurement methods.
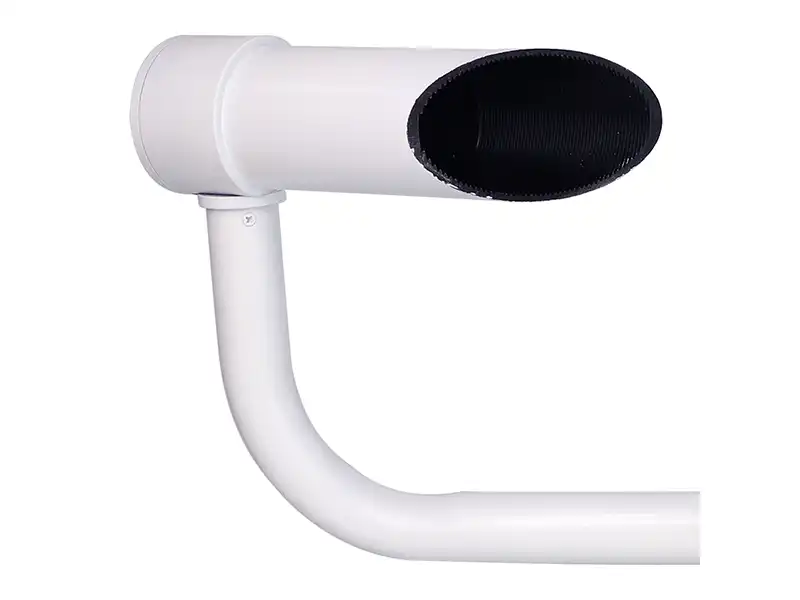
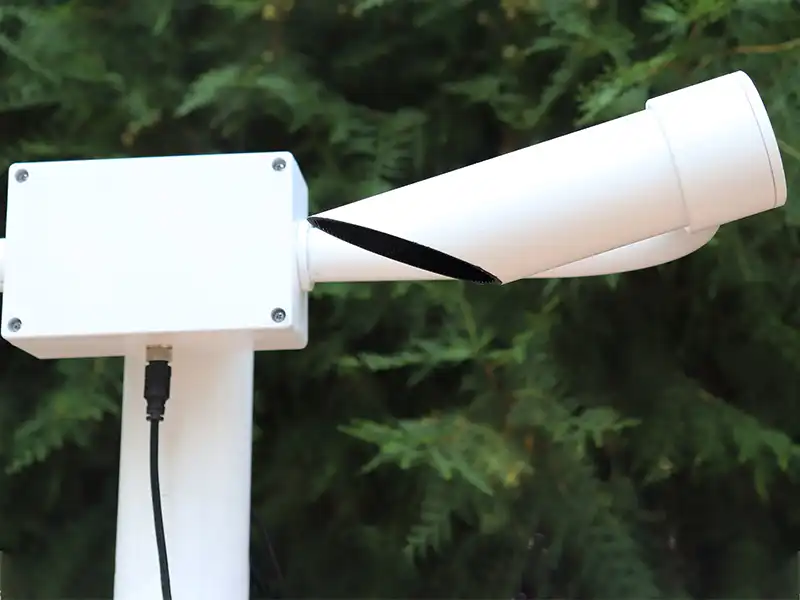
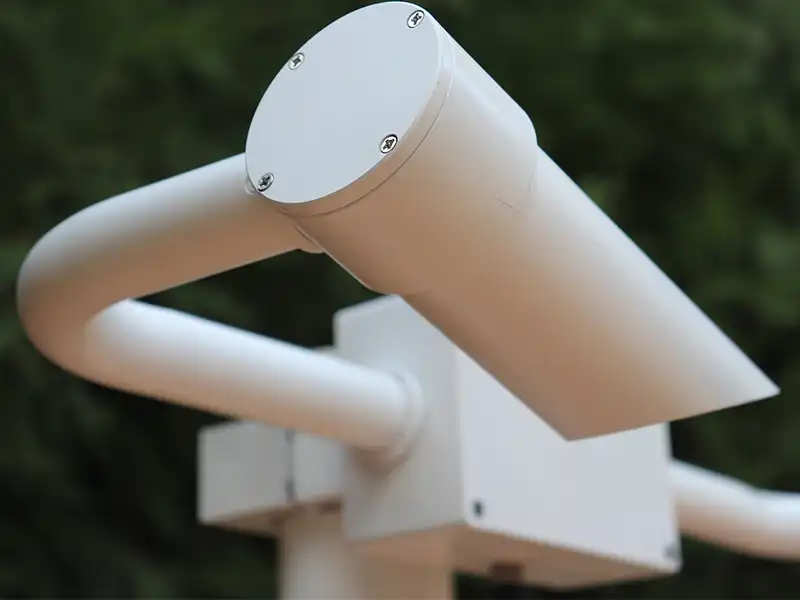
What Happens Inside a Fog Visibility Sensor?
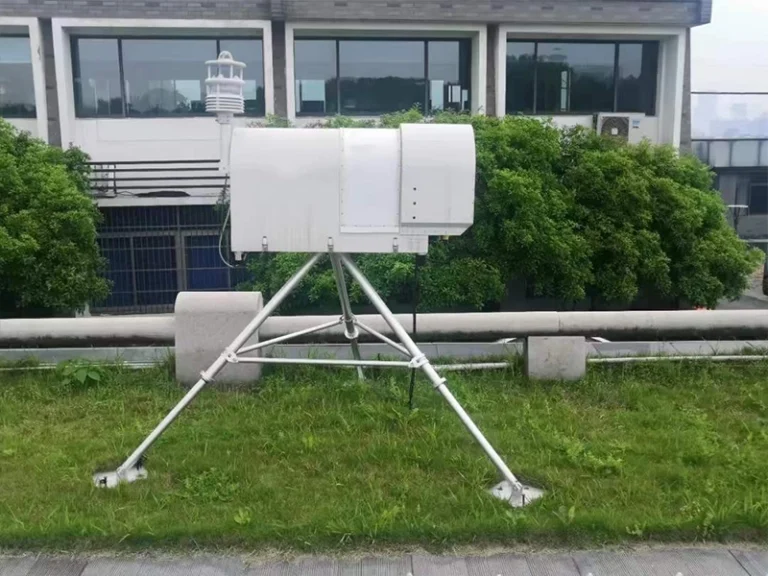
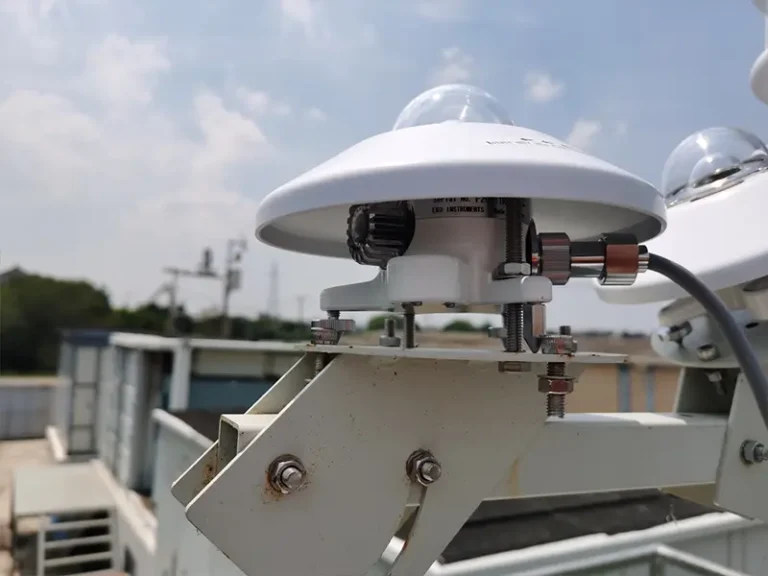
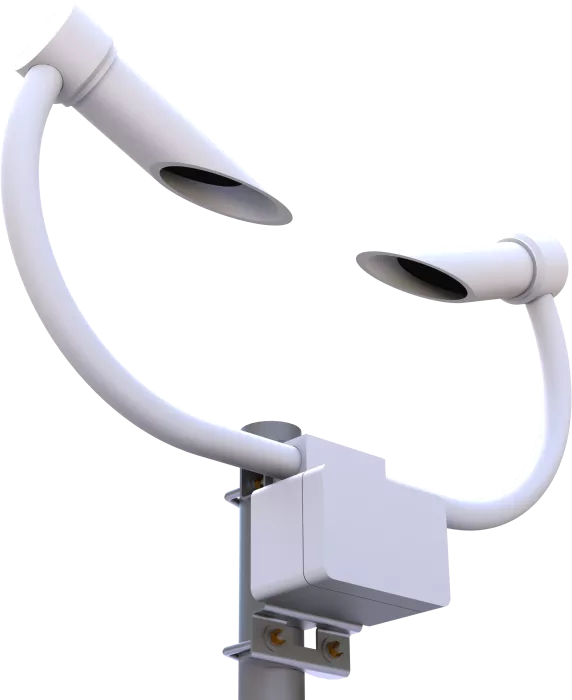
A roadside fog visibility sensor combines several components to maintain stable optical measurements in changing weather conditions. The main parts include the optical transmitter, optical receiver, signal processing unit, and optical protection system. Each component has a specific role, from generating and detecting the optical signal to processing the measurement and protecting the optical path.
Optical Transmitter
The optical transmitter provides a stable light source for the measurement area. Its light output, wavelength, modulation, and beam stability affect the quality of the scattered signal received by the sensor. For roadside use, the transmitter also needs to maintain consistent performance as temperature and weather conditions change.
Optical Receiver
The optical receiver detects the scattered light from the measurement area and converts it into an electrical signal for further processing. Its sensitivity, optical alignment, field of view, and resistance to ambient light all affect the quality of the measured signal. A stable receiver is especially important when visibility changes quickly during fog events.
Signal Processing Unit
The signal processing unit converts the electrical signal from the receiver into usable visibility data. It handles signal conditioning, filtering, calibration, and visibility calculation before sending the result through the sensor’s communication interface. This processing allows the sensor to distinguish the measurement signal from unwanted variations and provide a consistent visibility value to the monitoring system.
Optical Protection and Heating
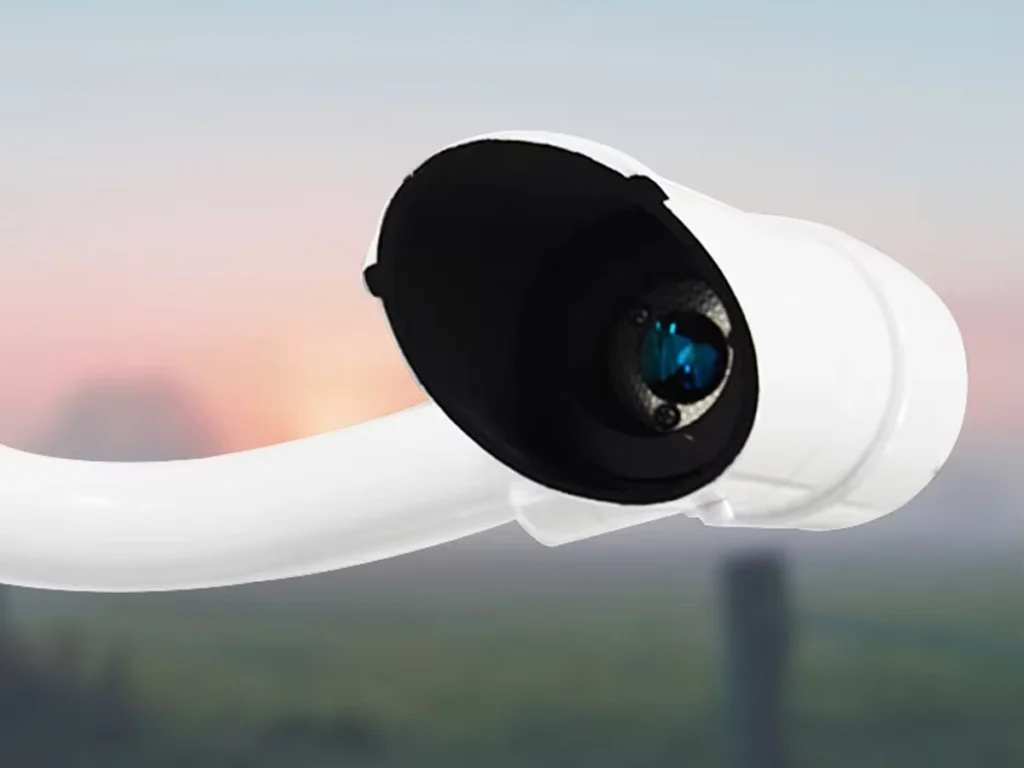
Roadside sensors operate in rain, snow, dust, sunlight, and large temperature changes, so protecting the optical path is an important part of the design. Condensation, frost, water droplets, or dirt on the optical window can change the received signal and affect the measurement. Depending on the design, protective housings, optical shielding, heating, and other measures can be used to keep the optical path clear during outdoor operation.
What Can Affect Fog Visibility Sensor Accuracy?
A fog visibility sensor measures optical conditions within a defined sampling volume, so its readings can be affected by local weather, unwanted light, installation conditions, and the state of the optical path. These factors are important when evaluating measurement accuracy and long-term performance.
Ambient Light and Stray Light
Sunlight, vehicle headlights, flashing beacons, and roadside lighting can enter the optical receiver and affect the measured signal. Optical shielding, stray-light suppression, and signal filtering can reduce these effects. Proper installation is also important, especially when the sensor is placed near traffic lanes or other strong light sources.
Weather Conditions and Optical Window Contamination
Rain, snow, fog, haze, smoke, dust, and road spray can change the optical conditions within the sampling volume. These may represent real causes of reduced visibility, while water droplets, frost, condensation, or dust on the optical window can additionally interfere with the measurement. Heating, defogging, shielding, and regular cleaning can help keep the optical path clear.
Installation and Maintenance
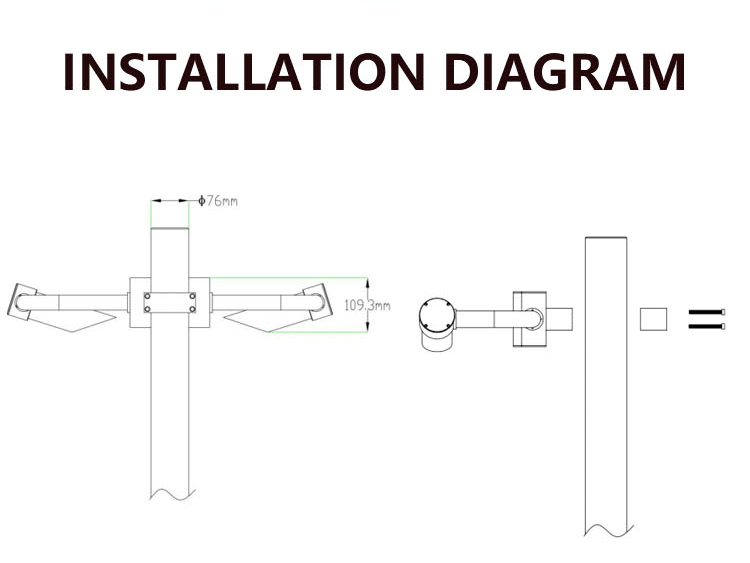
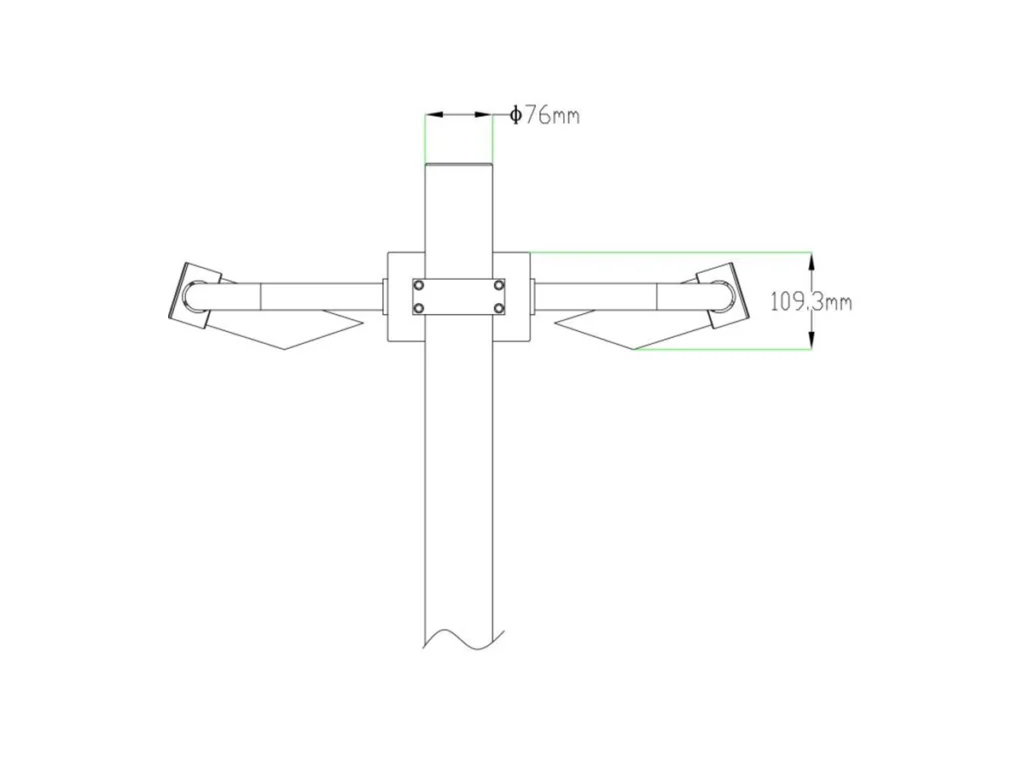
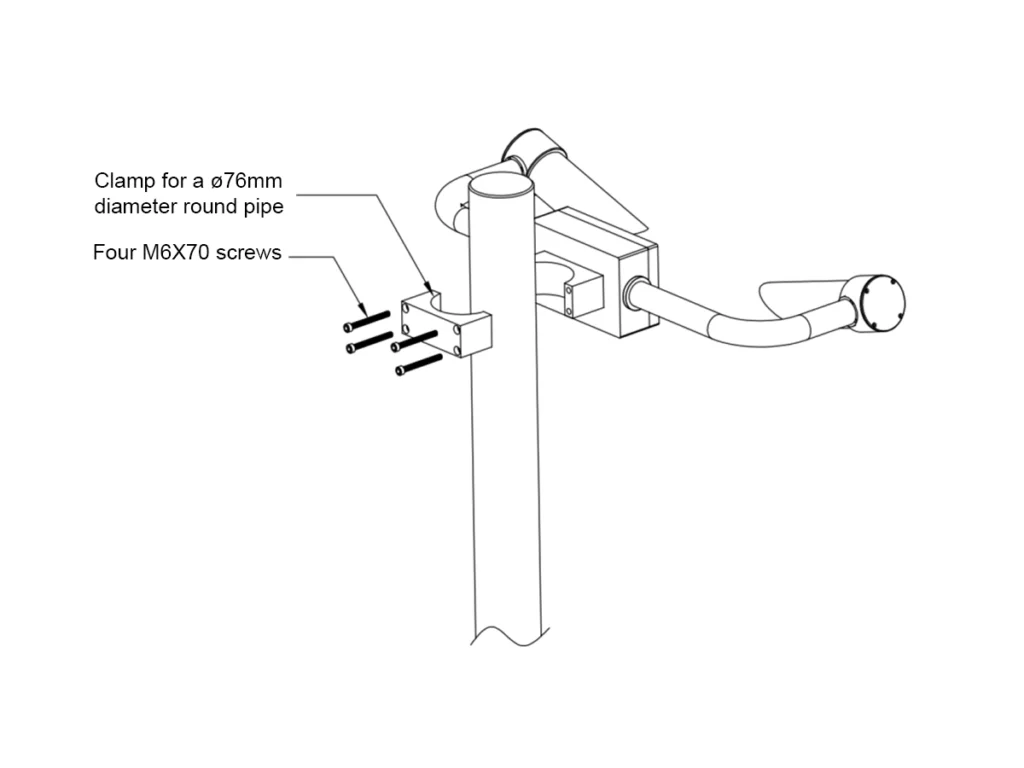
The sensor should be installed where the measurement volume is clear of nearby structures, vegetation, exhaust outlets, dust sources, and excessive water spray. Correct alignment and stable mounting are also important because visibility can vary considerably between different road sections. Regular inspection, optical-window cleaning, and calibration help maintain consistent measurements over long-term outdoor operation.
How Is a Fog Visibility Sensor Used in a Road Fog Monitoring System?
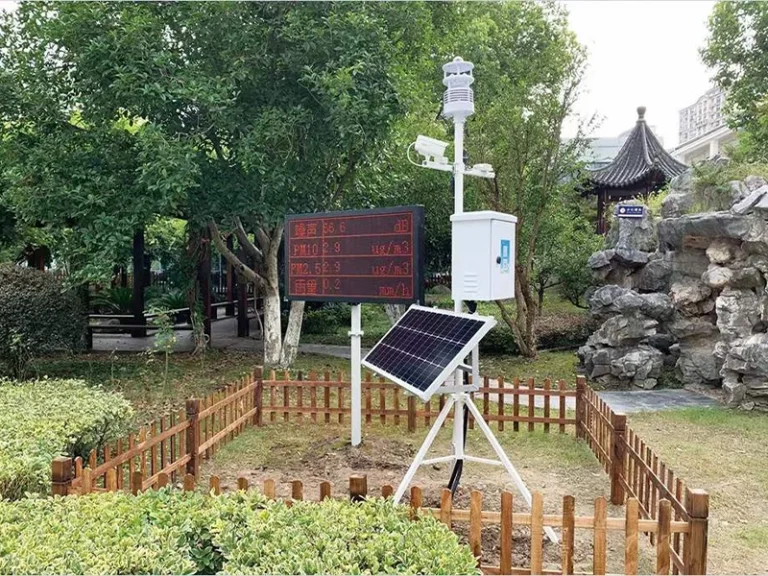
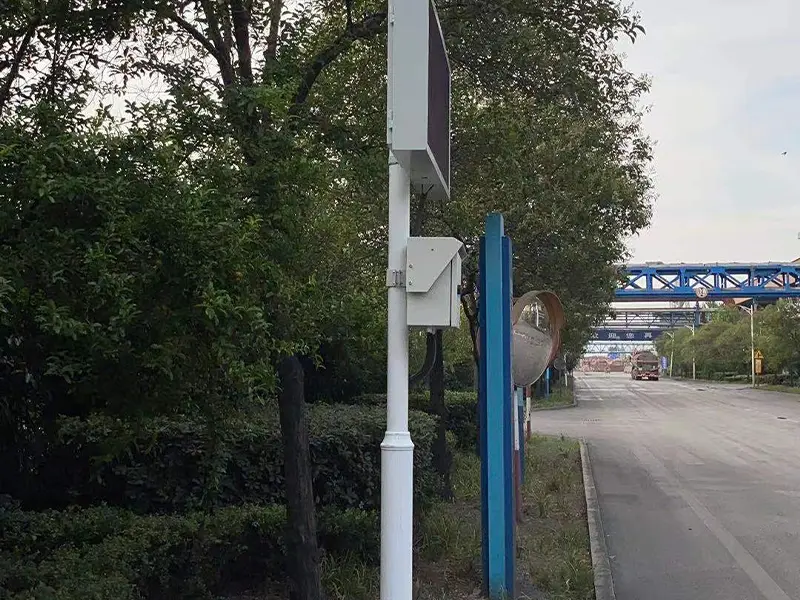
A fog visibility sensor is used as the field measurement device in a road fog monitoring system. It continuously measures road visibility and provides MOR data at selected roadside locations, then sends the measurements to a controller or data logger through interfaces such as RS485 and Modbus.
The collected data is then transmitted to a monitoring platform, where operators can view real-time visibility, track changes over time, and apply predefined thresholds to identify low-visibility conditions. Data from multiple sensors can also be combined to monitor visibility changes across different sections of a road.
When visibility reaches a defined warning level, the monitoring system can pass the information to Variable Message Signs (VMS), warning lights, traffic management centers, and emergency response systems. The sensor provides the measured visibility data, while the connected systems use it to support traffic warnings and road safety decisions.
Why Is Visibility Monitoring Important for Highway Safety?
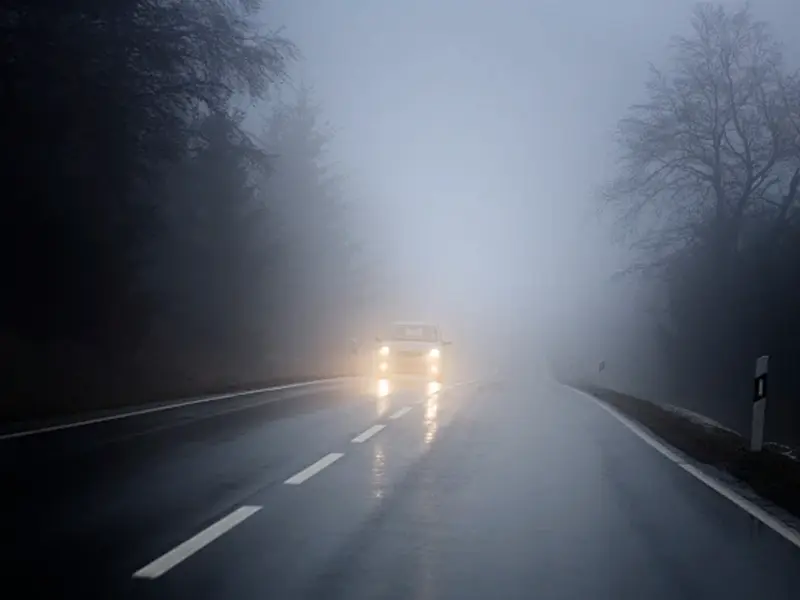
Visibility can change quickly on highways, especially around bridges, mountain roads, valleys, tunnel approaches, and water bodies. For road operators, the challenge is not simply knowing that fog is present, but knowing where visibility is changing and how quickly it is deteriorating. Continuous visibility monitoring provides localized field measurements for this purpose.
Detect Rapid Visibility Changes
Fog conditions can vary significantly over a short distance or within a short period. Terrain, wind, temperature, and moisture can create localized visibility changes that may not be reflected in regional weather observations. Continuous measurements make these changes visible as they develop, helping operators identify sections where visibility is deteriorating.
Support Early Warning
The measured visibility data can be compared with predefined warning thresholds. When visibility falls below a specified level, the system can generate an alert for operators to assess the conditions and initiate the appropriate response. This provides a continuous data basis for warnings instead of relying only on periodic manual observation.
Provide Data for Intelligent Traffic Systems
Visibility data can also feed into road weather information systems, traffic management platforms, Variable Message Signs (VMS), and other intelligent transportation systems. The basic chain is straightforward: sensor → data → decision. The sensor provides the field measurement, while connected systems use that information to support warnings, traffic control, and emergency response.
Where Are Fog Visibility Sensors Used?
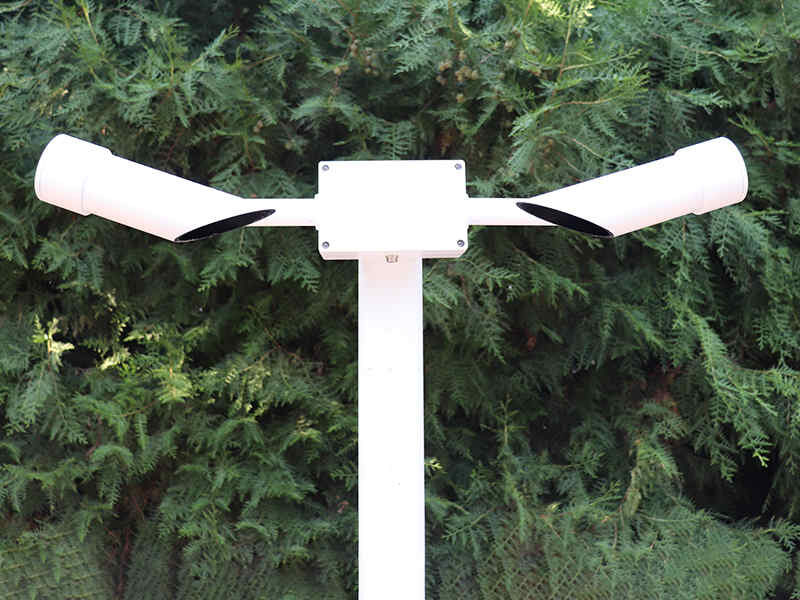
Fog visibility sensors are deployed where visibility can change quickly and where continuous, site-specific measurements are needed for road operations. In highway applications, typical locations include expressways, bridges, mountain roads, tunnel approaches, and road weather monitoring networks.
- Highways and Expressways — Installed along road sections prone to fog or other low-visibility conditions. Continuous measurements provide visibility data for roadside warnings, traffic management, and operational response.
- Bridges and Mountain Roads — Changes in terrain, elevation, wind, and moisture can create localized visibility conditions. A sensor provides measurements from the specific road section rather than relying only on wider-area weather observations.
- Tunnel Entrances and Exits — Rapid changes in atmospheric conditions can occur around tunnel approaches. Visibility measurements can support broader road-weather monitoring and help operators track changing conditions near the entrance or exit. They are not intended to serve as dedicated tunnel smoke detectors.
- Road Weather Information Systems (RWIS) — Visibility data can be combined with air temperature, humidity, precipitation, wind, and road-condition measurements to provide a broader view of road weather. See our [Road Weather Information System (RWIS)] guide for more details.
Beyond road applications, fog visibility sensors may also be deployed for weather observation, airport visibility monitoring, port operations, environmental research, and other specialized projects. Measurement range, installation requirements, and communication interfaces should be selected according to the application and site conditions.
What Should You Consider When Selecting a Fog Visibility Sensor?
For road fog monitoring, sensor selection should be based on more than measurement accuracy or range. The sensor needs to match the site’s visibility conditions, outdoor environment, monitoring system, and maintenance requirements. Before comparing specific models, check these six factors:
- Measurement Range — Match the sensor’s range to the visibility conditions expected at the site.
- Measurement Principle — Compare forward scatter and transmissometer designs based on the application, installation space, and monitoring requirements.
- Optical Protection — Check protection against condensation, frost, rain, snow, dust, and optical-window contamination.
- Environmental Rating — Verify the operating temperature, humidity, enclosure protection, and weather resistance.
- Communication Interface — Confirm compatibility with existing RS485, Modbus, RWIS, PLC, or data logger systems.
- Installation and Maintenance — Consider mounting, optical alignment, cleaning, calibration, and accessibility.
For most roadside projects, these factors should be evaluated together rather than separately. A suitable fog visibility sensor is one that fits the measurement requirements, site conditions, system architecture, and long-term maintenance plan of the project.
Conclusion
A fog visibility sensor measures optical scattering rather than distance directly, with forward-scatter technology providing a practical approach for continuous roadside visibility monitoring. Its value goes beyond the sensor itself: when integrated into a road fog monitoring system, the measured visibility data can support low-visibility warnings, traffic management, and broader road weather monitoring.
For highway, bridge, tunnel, and road-weather projects, sensor selection should match the required measurement range, optical protection, environmental conditions, installation requirements, and system interface. Yantai Sensor provides visibility monitoring sensors for different roadside applications and can support project-specific selection based on site conditions and system requirements. Contact us to discuss your road visibility monitoring project.